Architecture
System Overview
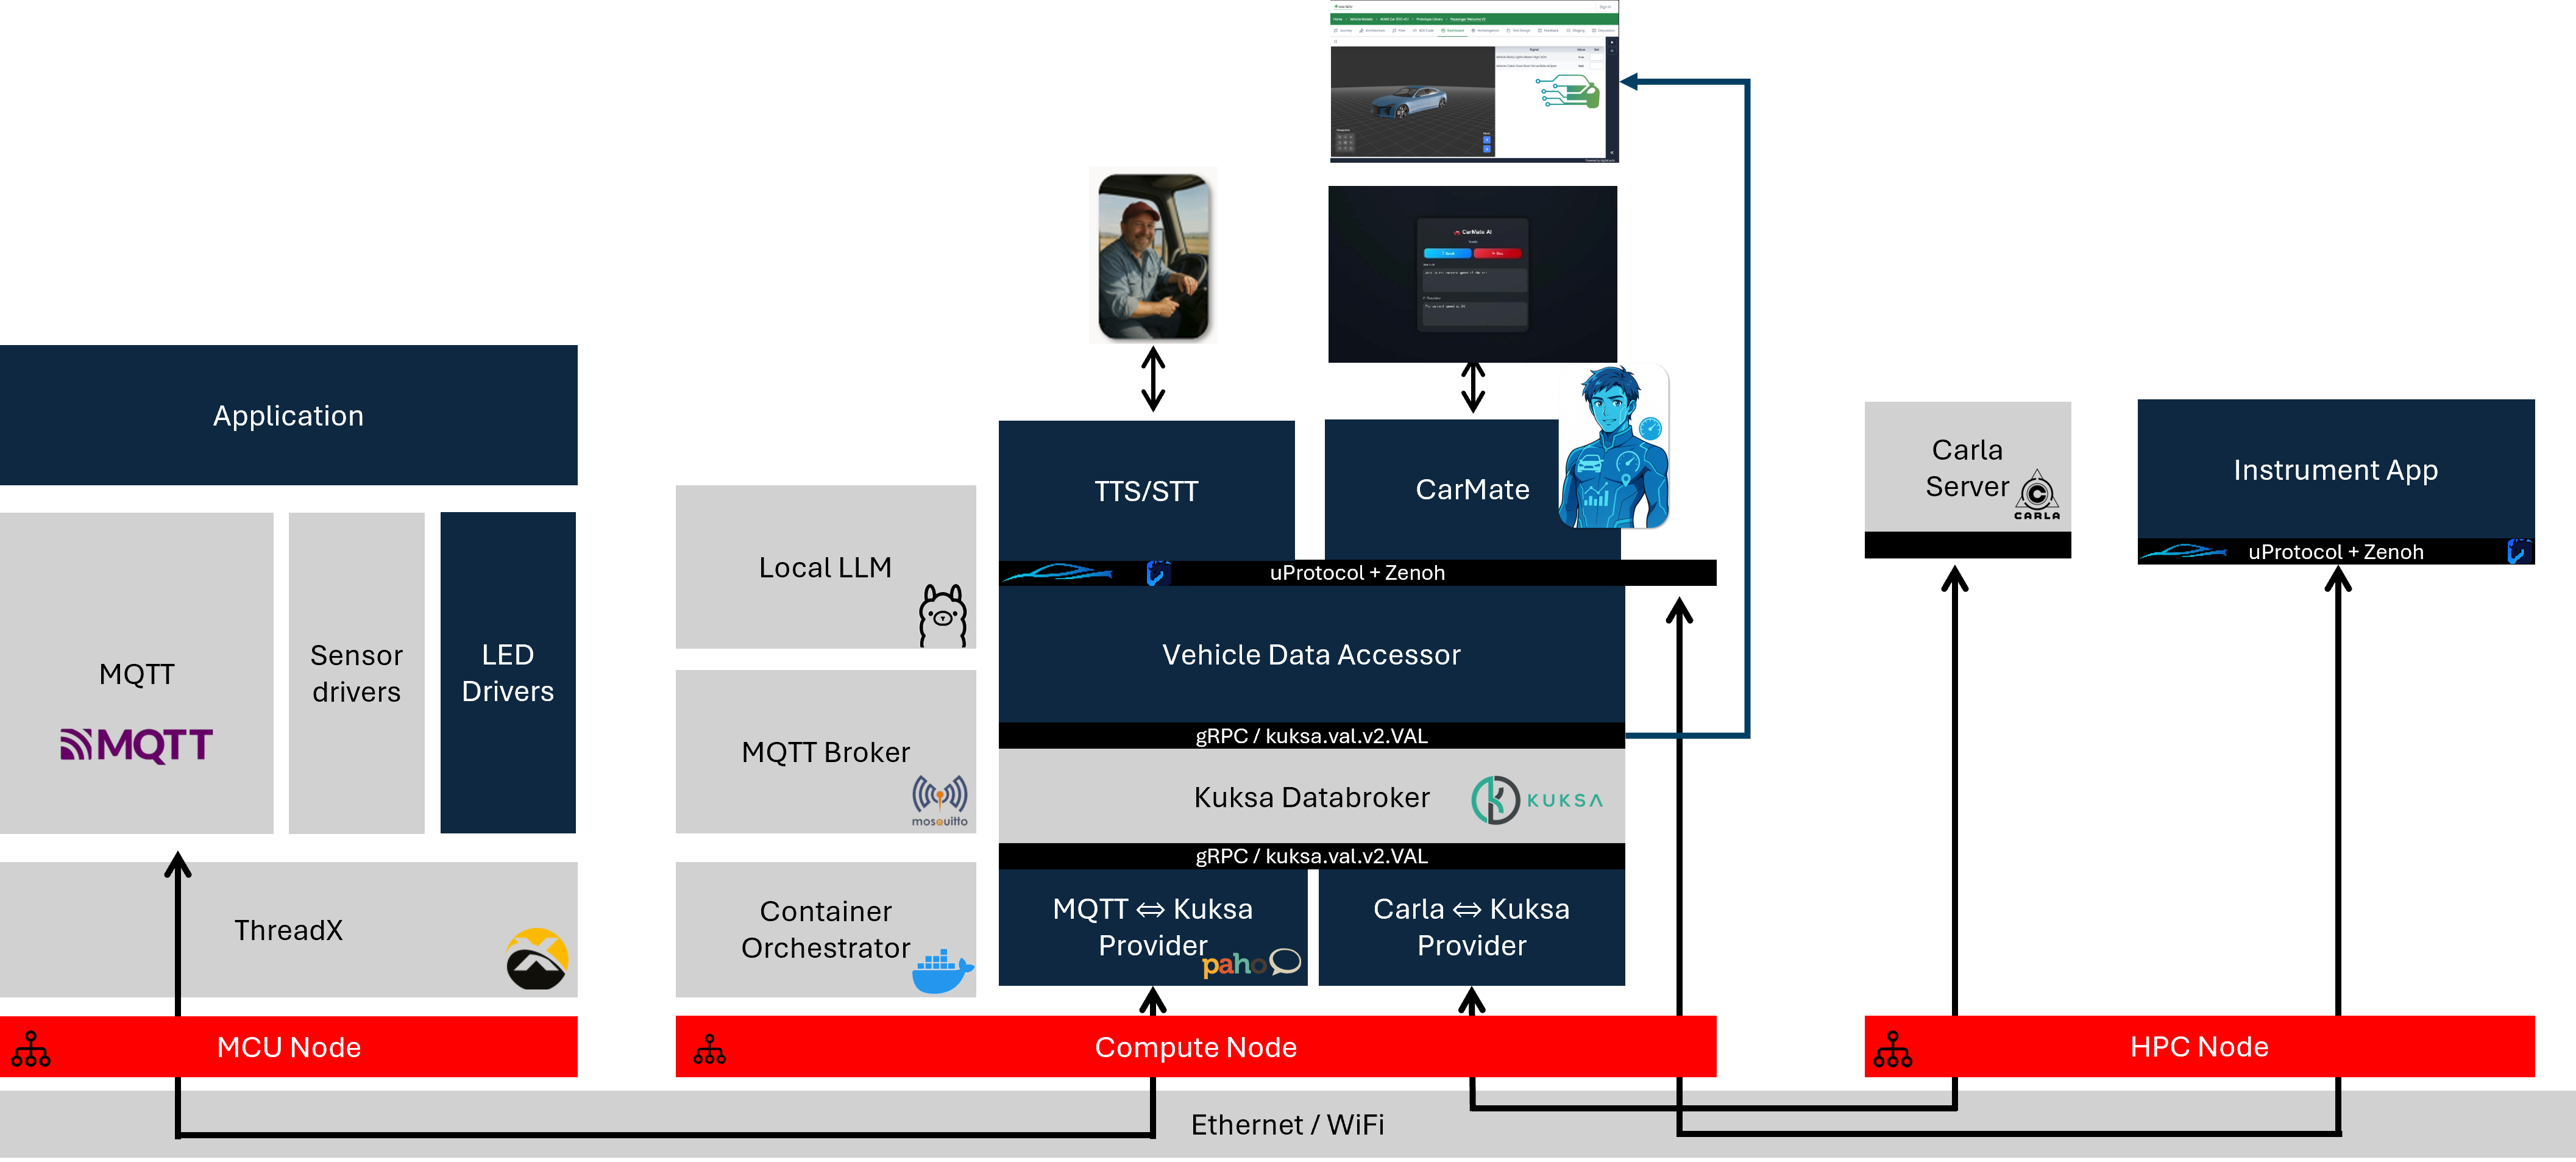
CarMate spans three connected nodes. Each node has a distinct role: hardware sensing, software-defined vehicle processing, and simulation/visualization.
Node Breakdown
MCU Node
| Property | Detail |
|---|---|
| Role | Hardware sensor acquisition and MCU-to-cloud telemetry publishing |
| Key Software | ThreadX RTOS, Rust firmware (threadx-app) |
| Key Hardware | Azure IoT Dev Kit (MXChip AZ3166) |
| Connectivity | Wi-Fi → MQTT to the Compute Node |
| Published Signals | Temperature (mcu/temperature) |
The MCU node runs a ThreadX-based Rust application that reads onboard sensors and publishes environmental data to the MQTT broker on the Compute Node over Wi-Fi.
Compute Node
| Property | Detail |
|---|---|
| Role | Central SDV processing node: signal brokering, AI reasoning, and driver interaction |
| Key Software | Docker Compose stack (8 containerized services) |
| Key Hardware | Linux machine (x86_64 or ARM64) |
| Connectivity | Ethernet to HPC Node, Wi-Fi to MCU Node |
The Compute Node hosts all containerized SDV services. It is the core of the CarMate blueprint and the minimum required node to run the system.
HPC Node
| Property | Detail |
|---|---|
| Role | Simulation environment and instrument cluster visualization |
| Key Software | CARLA 0.9.16, instrument display application |
| Key Hardware | Windows machine (dedicated GPU recommended) |
| Connectivity | Ethernet → MQTT to the Compute Node; uProtocol/Zenoh to CarMate I/O |
| Published Signals | Speed, Latitude, Longitude, Altitude, Road Wetness |
The HPC Node runs the CARLA driving simulator, which generates realistic vehicle dynamics. A CARLA-to-MQTT bridge on the Compute Node reads this data and forwards it as VSS-aligned signals.
Data Flow
The following describes the end-to-end signal path from sensor hardware through the SDV stack to the driver-facing AI:
MCU Sensors → Wi-Fi MQTT → MQTT Broker
CARLA Simulator → Ethernet MQTT → MQTT Broker
                                       │
                              MQTT-Kuksa Provider
                                       │
                                  Zenoh Router
                                       │
                             Eclipse Kuksa Databroker
                             (VSS-aligned signal store)
                                       │
                           Vehicle Data Accessor (gRPC)
                                       │
                              CarMate Agent (LLM)
                                       │
                    ┌──────────────────┴──────────────────┐
              CarMate I/O                          Vehicle systems
          (STT - TTS - Web UI)                  (ambient lighting, etc.)
                    │
                 Driver
All vehicle signals flowing through the Compute Node are normalized to COVESA VSS paths inside the Kuksa Databroker:
| MQTT Topic | VSS Signal Path | Unit |
|---|---|---|
carla/vehicle/speed | Vehicle.Speed | km/h |
carla/vehicle/lat | Vehicle.CurrentLocation.Latitude | ° |
carla/vehicle/lon | Vehicle.CurrentLocation.Longitude | ° |
carla/vehicle/alt | Vehicle.CurrentLocation.Altitude | m |
carla/vehicle/wetness | Vehicle.Exterior.Humidity | % |
mcu/temperature | Vehicle.Cabin.HVAC.AmbientAirTemperature | °C |
Component Interaction
| Component | Node | Function | Technology |
|---|---|---|---|
| Eclipse AutoWRX SDV Runtime | Compute | Middleware orchestration and service lifecycle management | Docker, AutoWRX |
| Eclipse Mosquitto | Compute | Central MQTT message broker for all sensor topics | Eclipse Mosquitto 2.0 |
| Eclipse Zenoh Router | Compute | uProtocol transport layer; connects services via pub/sub and RPC | Eclipse Zenoh |
| MQTT-Kuksa Provider | Compute | Subscribes to all MQTT sensor topics and forwards values to Kuksa via Zenoh | Python, paho-mqtt, kuksa-client |
| CARLA-Kuksa Provider | Compute | Bridges CARLA simulation (or mock data) to MQTT topics | Python, carla, paho-mqtt |
| Eclipse Kuksa Databroker | Compute | VSS-based central vehicle signal store; provides gRPC API | Eclipse Kuksa |
| Vehicle Data Accessor | Compute | Reads VSS signals from Kuksa Databroker and exposes them to the CarMate Agent | Python, kuksa-client |
| CarMate Agent | Compute | Receives driver queries via uProtocol RPC, queries vehicle context, calls LLM, and returns responses | Python, uProtocol, Ollama/OpenAI/Gemini |
| CarMate I/O | Compute | Flask web application providing the driver Web UI, STT/TTS pipeline, and cluster display | Python, Flask, SpeechRecognition |
Driver Interaction Sequence
The following sequence diagram shows a complete driver interaction — from a spoken query to an AI-generated spoken response:
Communication Protocols
| Protocol | Usage in CarMate |
|---|---|
| MQTT | Sensor data ingestion from CARLA and MCU to the Compute Node |
| Eclipse Zenoh | Internal uProtocol transport between Compute Node services |
| uProtocol (RPC) | CarMate I/O → CarMate Agent request/response calls |
| gRPC | Vehicle Data Accessor → Kuksa Databroker signal reads |
| HTTP / REST | CarMate I/O Flask web application for the driver browser UI |
| Wi-Fi | MCU Node to Compute Node MQTT communication |
| Ethernet | HPC Node (CARLA) to Compute Node MQTT communication |